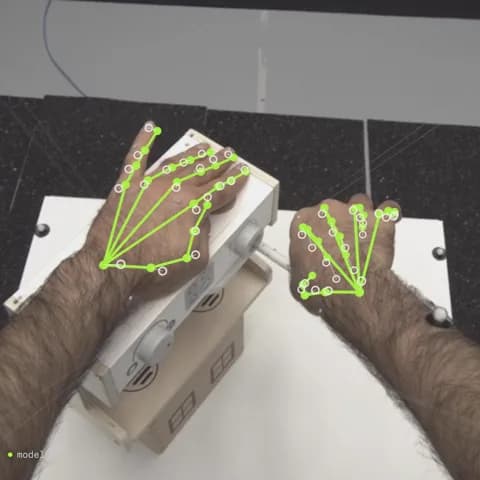
MC-EgoHands
A frontier 3D harness for human egocentric video.
 Read more

Real-world egocentric data and high-fidelity simulation at scale for training, evaluating, and deploying robots.
01 Mission
Physical AI produces impressive demos. Yet very few robots ever reach the real world.
Scaling robotics now requires:
Human action data at internet scale for pretraining.
Reliable simulation for evaluation and RL.
Midcentury builds both.
The next industrial revolution begins when robots leave the lab.

02 Datasets
Large-scale robotics and simulation data, paired with rich action supervision and dense annotations for the next generation of physical AI.
One of the largest unscripted egocentric datasets across industrial and everyday environments. Video, IMU, and audio enriched with 3D hand pose, point tracks, depth, and task annotations.
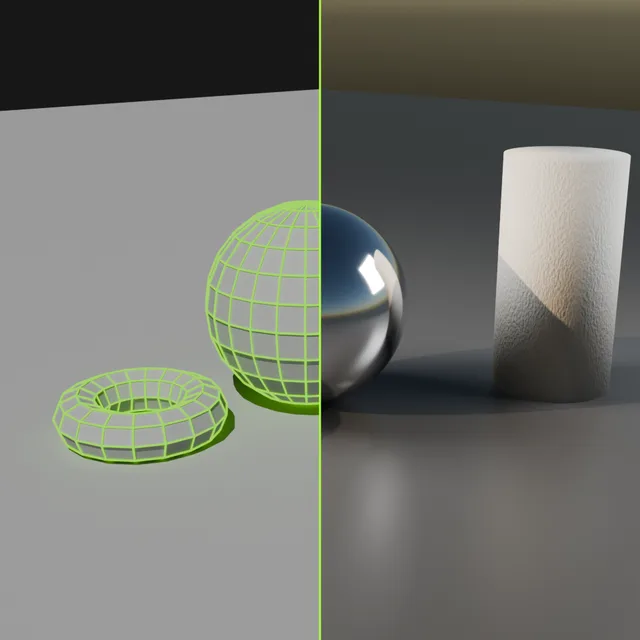
Custom, on-demand gameplay data from environments built to spec — any camera angle from first-person to top-down — with frame-aligned inputs, telemetry, camera state, and engine G-buffers.
03 Simulation
Agentic simulation platform to design, test, and train physical AI across massively parallel cloud environments.
01 Design
Digital twins from real deployment conditions, combining classical simulation with learned physics.
02 Test
Massively parallel GPU evaluation across thousands of scenarios. Replay failures, catch regressions before hardware.
03 Train
Turn failures into new scenarios and training experience. Feed real-world data back into policies.
04 Research
A frontier 3D harness for human egocentric video.
Read moreA time-to-failure physics benchmark for world models.
Read more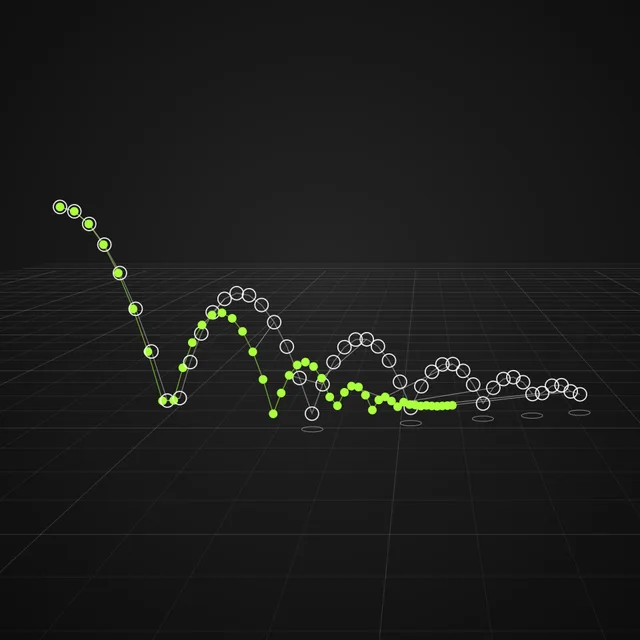
Real-time photorealistic rendering for any simulation.